



- by SteveJames
Does a Torque Sensor Stop Rear Shock Bobbing?
- by SteveJames
E-Bikes
Accessories
 Free Shipping
 15-Day Returns
 2-Year Warranty
Free Shipping
15-Day Returns
2-Year Warranty
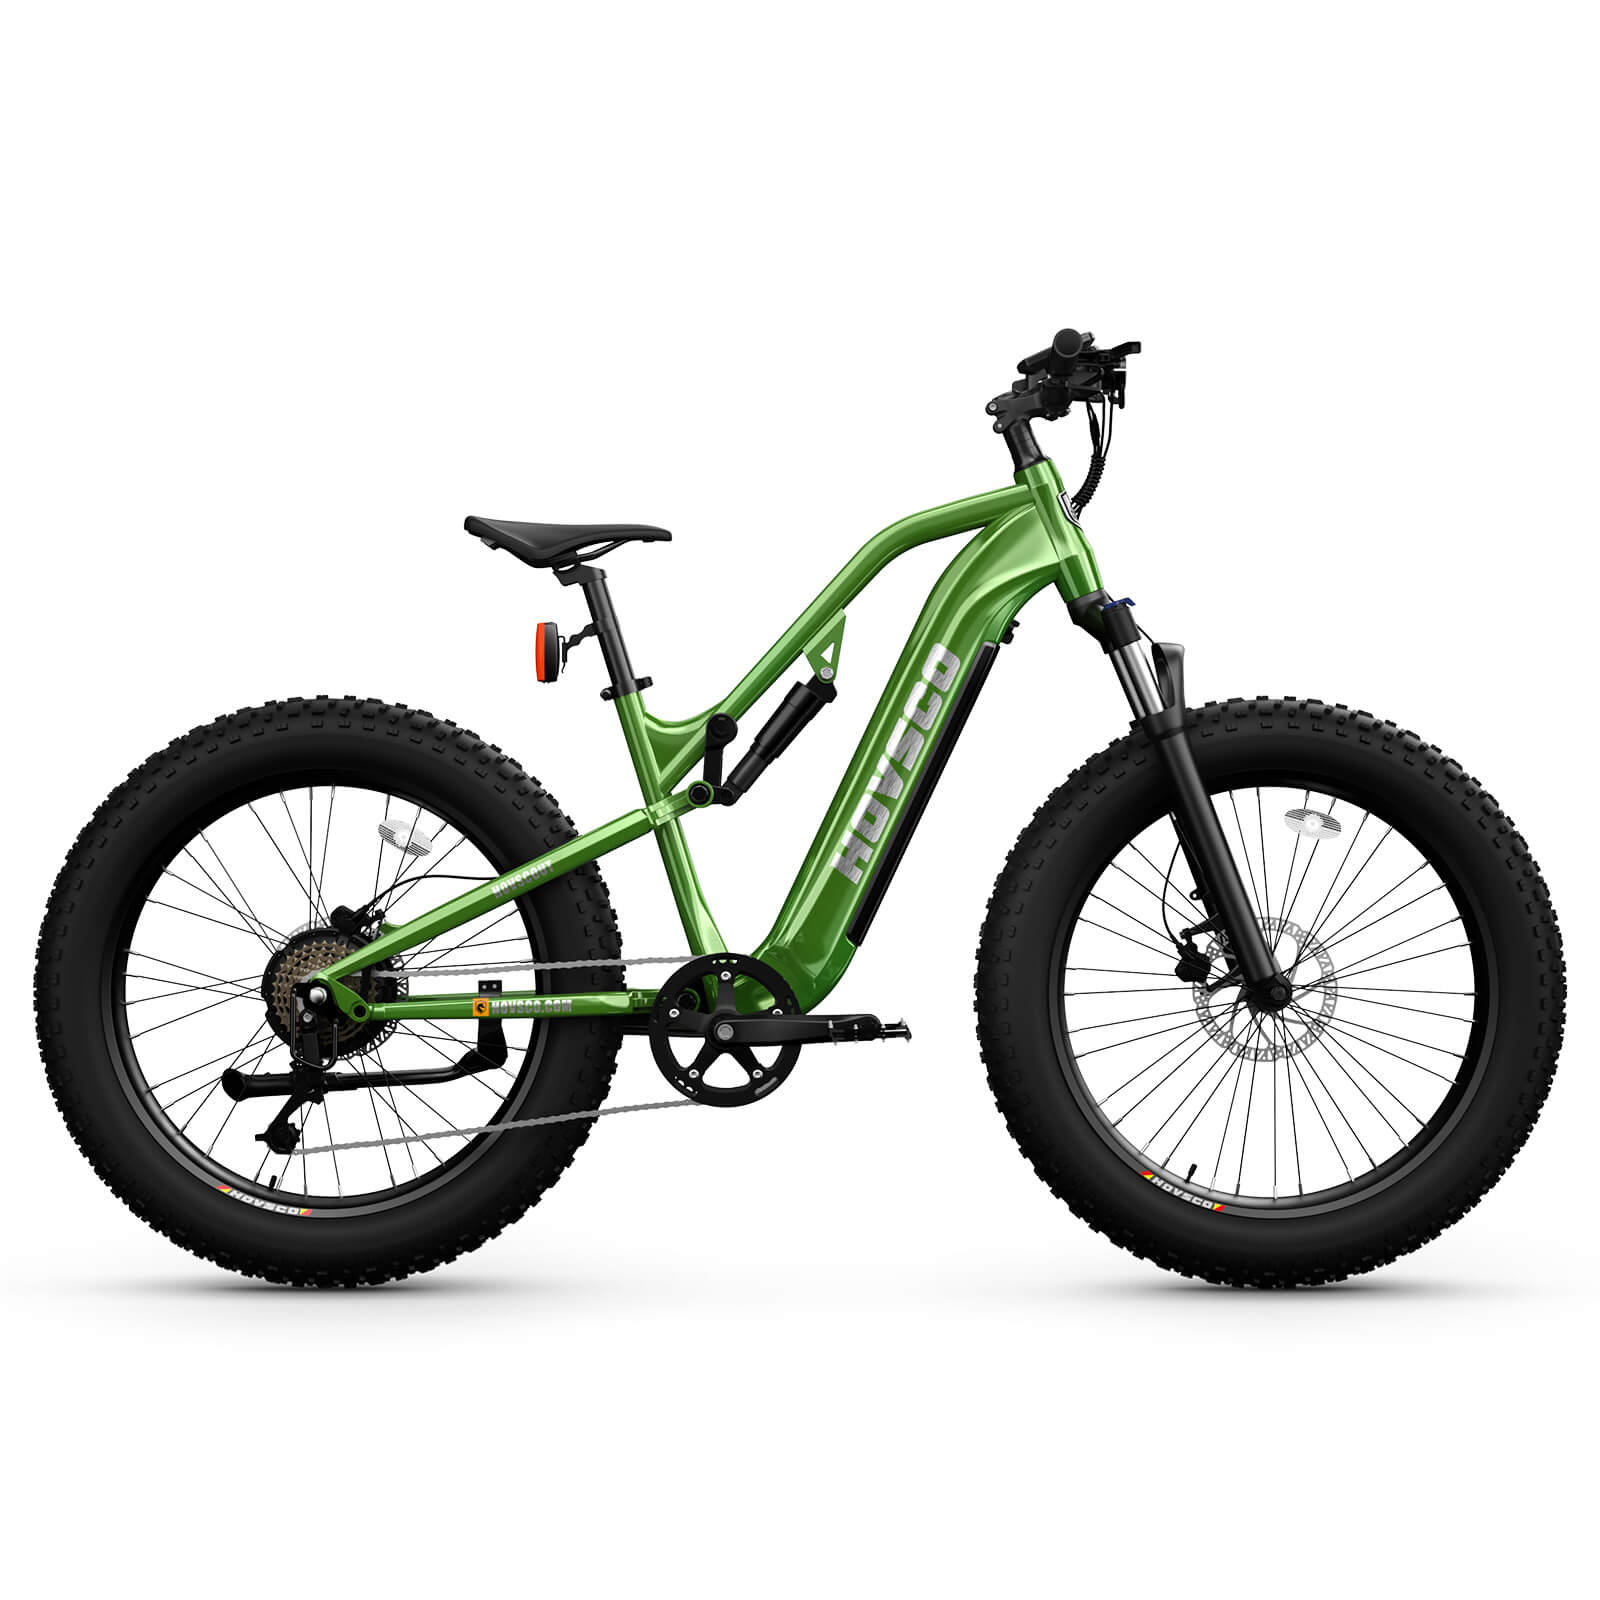
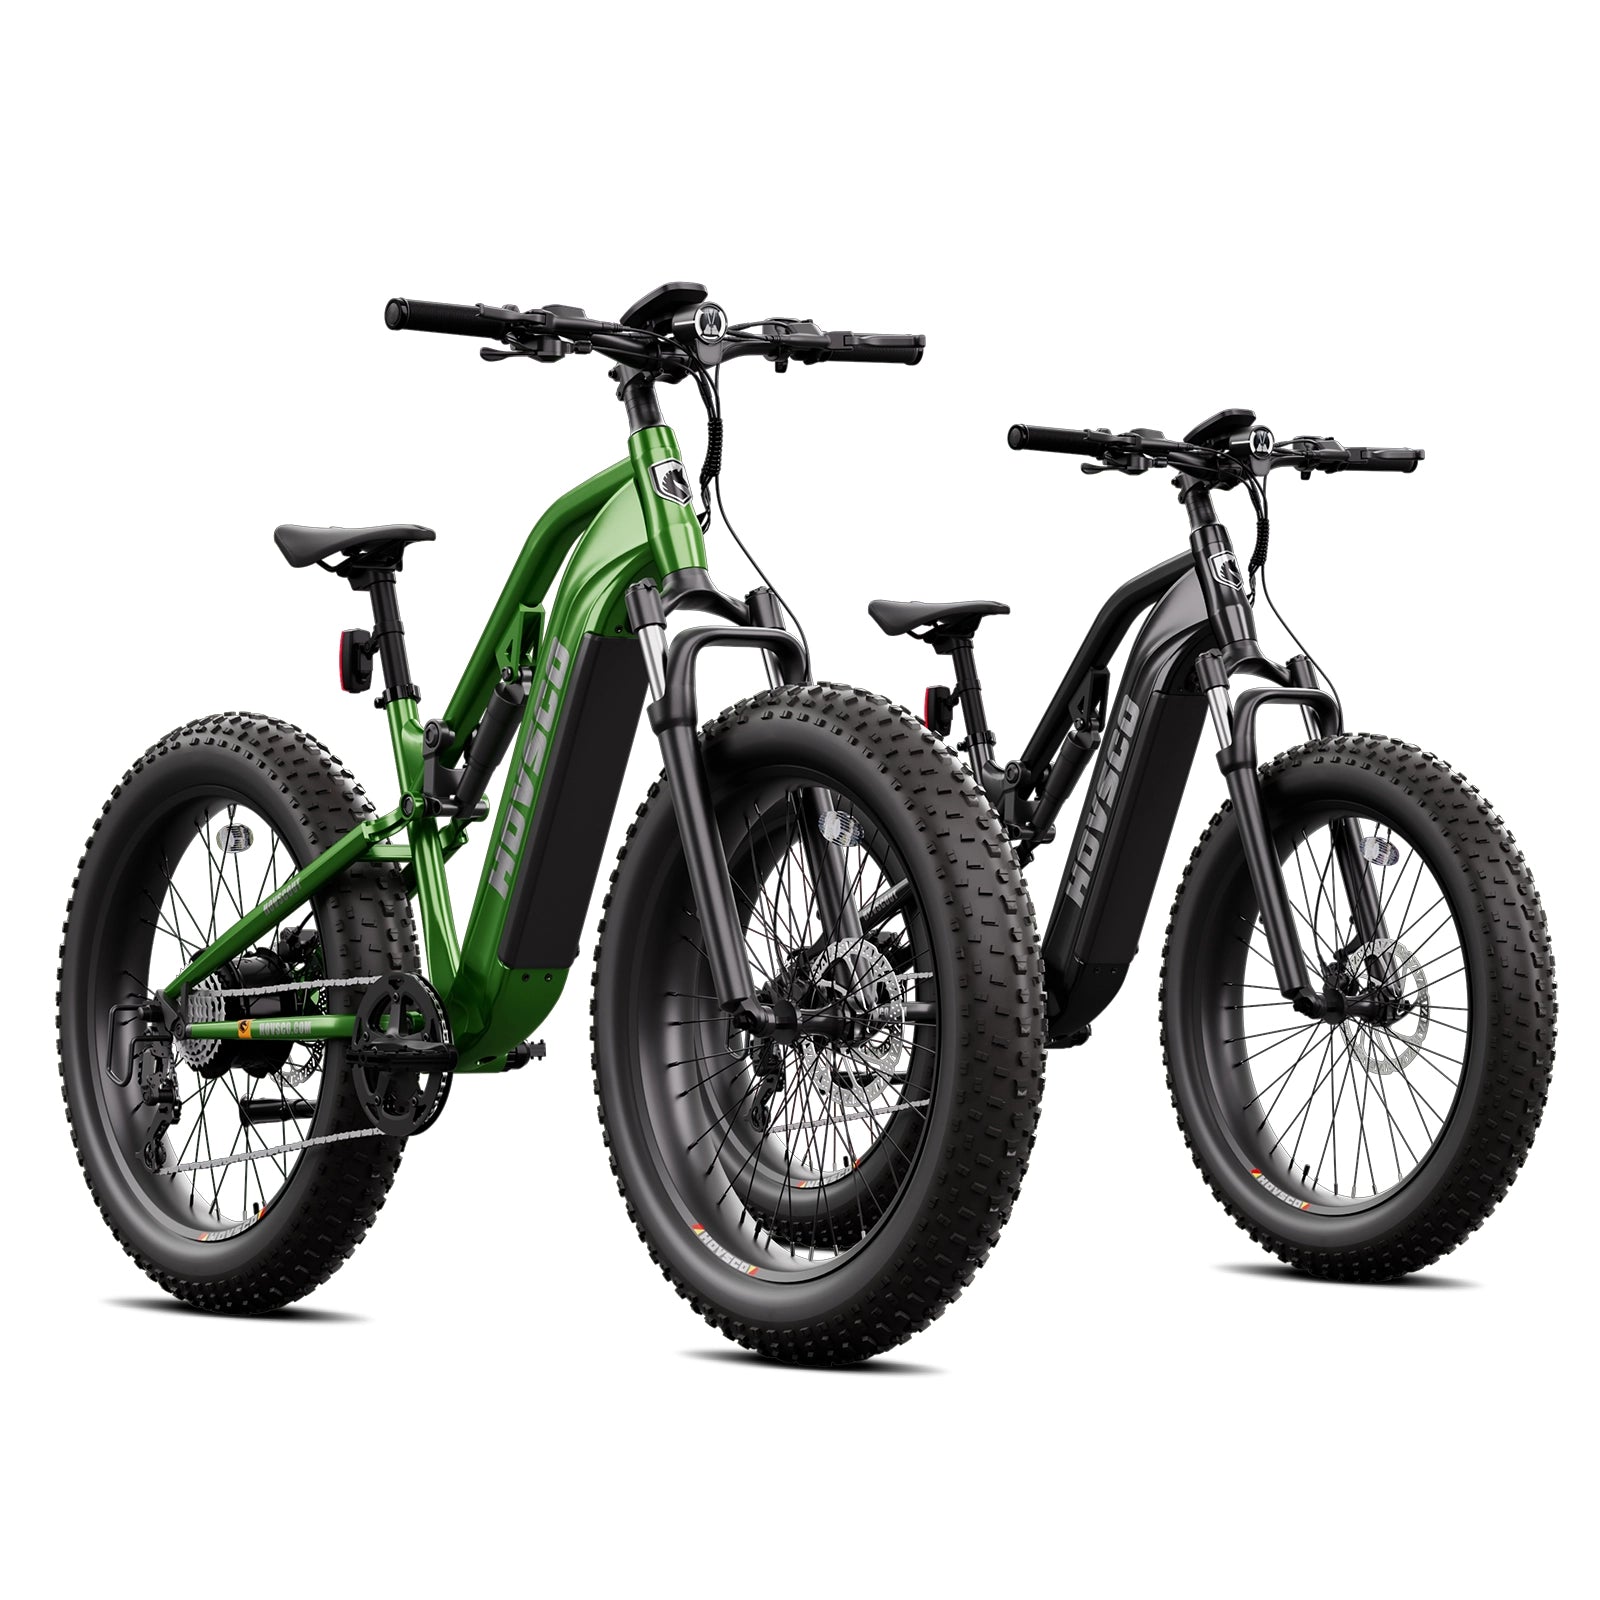
A torque sensor can greatly reduce pedal bob on a full-suspension e-bike because it measures rider input more directly and lets the motor match real pedaling force instead of overreacting to cadence spikes. When tuning is done well, the bike feels calmer, more natural, and less likely to pitch fore-and-aft on rough ground. HOVSCO-style torque control is strongest when motor response, suspension sag, and damping are calibrated as one system.
eliminate pedal bob on soft tail bikes
Pedal bob happens when rider power, motor assist, and rear suspension all interact out of phase. Each pedal stroke loads the suspension, the suspension rebounds, and the motor may add power at the wrong moment, which amplifies fore-and-aft motion. On low-end cadence-based systems, the assist can feel like an on/off push that exaggerates this cycle instead of smoothing it.
In practice, bob is not just a suspension problem. It is a control problem, a frame kinematics problem, and a tuning problem all at once. That is why two bikes with the same travel can feel completely different under the same rider. HOVSCO riders often notice that a well-tuned torque system feels quieter and more planted even before they think about the shock.
A torque sensor reads how hard you are pushing, not just whether the cranks are turning. That lets the controller scale motor output to real leg force, so assist rises and falls in a way that tracks your body rather than merely your cadence. The result is smoother power delivery, fewer surge spikes, and much less “fight” between the motor and the suspension.
The key advantage is timing. When pedal force is sensed early and continuously, the controller can avoid dumping extra power into the bike right as the rear triangle is compressing or rebounding. This is why HOVSCO and other premium e-bike brands favor torque-based feel for trail riding, technical climbing, and mixed-terrain use.
Low-end cadence sensors often detect rotation without understanding force. That means the motor can continue pushing even when the rider is unloading the pedals through a compression, which creates a pogo-like rhythm on a full-suspension frame. Instead of helping the bike settle, the assist can add energy exactly when the rear shock is trying to absorb it.
Here is the practical difference:
The disaster case is not “cadence sensing” by itself. The real problem is poor tuning, low sampling quality, and a controller that cannot coordinate motor ramp rate with suspension movement. On rough climbs, that mismatch feels like the bike is “nodding” forward and backward with every pedal stroke.
The most important tuning detail is assist ramp rate, because it determines how fast motor torque rises after you push the pedals. If ramp-up is too aggressive, the bike surges before the suspension settles. If it is too slow, the rider feels lag and compensates with harder pedaling, which can also trigger bob.
A second detail is torque resolution near the low end. The best systems respond clearly to subtle force changes, so the motor can support you without jumping from weak to strong in one step. That is especially important in full suspension frames where small changes in pedal load can translate into visible chassis motion.
Rear shocks do not only absorb impacts; they also absorb part of the rider’s input energy. When the rider stands and torques the bike, the rear end compresses slightly, changes chain tension, and then rebounds. If motor assist is based on crude input detection, the controller may misread this oscillation as a new request for power.
That is why a refined system treats suspension movement as part of the control loop rather than an afterthought. In my experience, the best rides happen when motor response is calm enough to let the shock do its job, but responsive enough to preserve traction. HOVSCO’s brand direction has increasingly reflected this philosophy: stable power, predictable feel, and less wasted motion.
Sampling and damping need to be synchronized because the bike’s mechanical response changes within fractions of a second. If the controller reads torque too slowly, it reacts after the suspension has already moved, so the assist arrives late and piles energy onto the rebound. If it reads and filters too aggressively, the bike can feel filtered-out and lifeless.
Think of it as a timing chain between your legs, the motor, and the shock. The cleaner the timing, the less the bike oscillates. The more the controller “waits and sees,” the more the frame can drift into a visible rhythm that riders describe as bob, porpoising, or drivetrain chatter. That is why the phrase “microsecond-level synchronization” matters as an engineering aspiration, even if real-world behavior still depends on frame stiffness, shock valving, and firmware logic.
Yes, an 80Nm torque platform can support full-suspension riding very effectively when the controller is tuned for smooth delivery rather than raw punch. High torque alone does not solve bob; what matters is how gently and intelligently that torque is released. HOVSCO’s appeal is not just peak force, but the way the system can feel composed when climbing, accelerating, and riding over broken terrain.
For riders, that means three things. First, steep climbs become easier without constant gear hunting. Second, traction improves because the wheel is less likely to spin when the suspension is active. Third, the bike feels more like an extension of the body than a machine trying to outrun the terrain. HOVSCO, HOVSCO, HOVSCO is strongest when power delivery and chassis behavior are treated as one design problem.
Buyers should look beyond motor wattage and ask how the system behaves under load on rough ground. The most useful questions are whether the bike uses a torque-based assist strategy, how quickly assist ramps in, and whether the suspension tuning was designed with motor support in mind. A strong spec sheet can still hide a sloppy ride if the control logic is crude.
Also check frame geometry, anti-squat balance, and shock support. A good torque sensor cannot fully rescue a frame that is too soft in the rear or a controller that overfeeds power. In other words, the best e-bike experience comes from system integration, not from one impressive number on a page.
“A great full-suspension e-bike should never feel like the motor and rear shock are arguing with each other. In our view, torque sensing is not just about power delivery; it is about ride harmony. When the controller respects rider force and the suspension’s natural motion, the bike climbs cleaner, tracks better, and wastes less energy. That is the standard we push toward at HOVSCO.”
Start with sag, because incorrect sag causes the shock to sit too deep or too high in its travel and makes bob worse. Then reduce assist aggression in the lowest modes so the motor supports rather than launches you. Finally, use a smoother cadence and seated pedaling on technical climbs, because standing and mashing can amplify oscillation even on a good system.
A practical setup sequence works best:
Set rear sag correctly for your weight and riding style.
Test the lowest and middle assist modes on a climb.
Check whether the bike surges when you transition from seated to standing.
If it does, reduce ramp aggressiveness before changing shock settings.
Re-test on the same hill, because consistency matters more than theory.
The goal is not to eliminate all movement. The goal is to make movement controlled, efficient, and quiet.
Yes, the sensor can dramatically affect feel because it changes how the bike interprets your pedaling intent. A poor sensor makes the assist feel delayed or abrupt, while a good torque sensor makes the bike feel like it is reading effort rather than motion. That difference is especially obvious on a full-suspension e-bike where the rear end is constantly changing load.
For riders, the sensation is simple: less lurch, more flow. For engineers, the challenge is harder, because the system must balance detection speed, filtering, durability, and thermal stability. That is where high-quality HOVSCO engineering language matters: not as marketing fluff, but as a commitment to consistent ride behavior.
The death of pedal bob is not about one magic part. It is about pairing a responsive torque sensor with a suspension system and controller that speak the same language. When assist output is proportional, well timed, and calm, the bike stops fighting itself and starts feeling planted, efficient, and fast.
For buyers, the lesson is clear: do not chase only peak torque. Look for torque sensor quality, smooth ramping, and full-suspension tuning that respects trail physics. That is the difference between a bike that surges and a bike that flows.
What is pedal bob on an e-bike?
Pedal bob is the fore-and-aft bouncing caused by pedaling forces compressing and rebounding the rear suspension.
Why is a torque sensor better than cadence sensing for full suspension?
A torque sensor measures force, so assist feels proportional and less likely to trigger unwanted suspension oscillation.
Does higher torque always mean more bob?
No. Poor tuning causes bob, not torque alone. A well-calibrated high-torque system can still feel very stable.
Can HOVSCO help with climbing on rough trails?
Yes. A torque-based HOVSCO setup can improve traction, reduce surge, and make technical climbs feel smoother.
How do I reduce bob on my bike today?
Check sag first, soften assist ramp if possible, and test on the same climb so you can isolate each change.
Share:
How Do You Prevent Air Shock Blowouts?